publications

All publications, newest first. Preprints are marked arXiv.

2026

  1. ACL
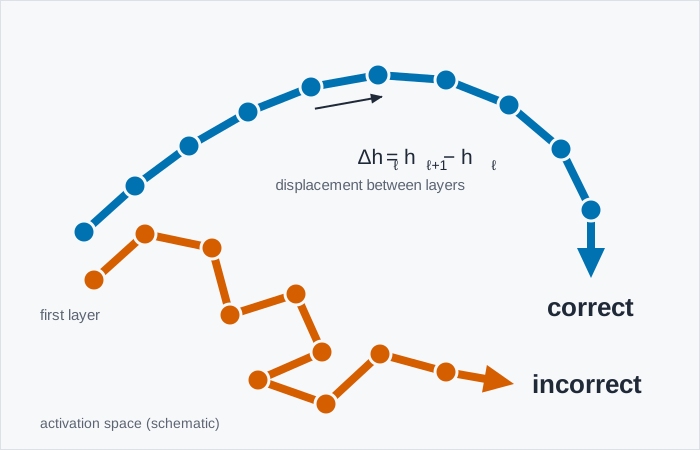
    truth-trajectory.svg
    Truth as a Trajectory: What Internal Representations Reveal About Large Language Model Reasoning
    Hamed Damirchi, I. Meza De la Jara, E. Abbasnejad, A. Shamsi, Z. Zhang, and J. Q. Shi
    In Proceedings of the 64th Annual Meeting of the Association for Computational Linguistics (Long Papers), 2026
  2. arXiv
    Reasoning Errors Have a Region and a Direction in the Residual-Stream Trajectory of LLMs
    Hamed Damirchi, I. Meza De la Jara, D. Ranasinghe, Y. Liu, and J. Shi
    arXiv preprint arXiv:2608.05660, 2026
  3. arXiv
    Representation Trajectories Matters: Complementary Evidence for OOD Detection and Image Classification
    I. M. De la Jara, C. Rodriguez-Opazo, Hamed Damirchi, S. Gould, and D. Ranasinghe
    arXiv preprint arXiv:2607.26565, 2026
  4. arXiv
    Vertical Fusion: Condensing Internal Representations for Robust ViT Classification
    F. Di Salvo, S. N. Rai, Hamed Damirchi, I. Meza De la Jara, S. Doerrich, M. Lents, and C. Ledig
    arXiv preprint arXiv:2607.10391, 2026

2025

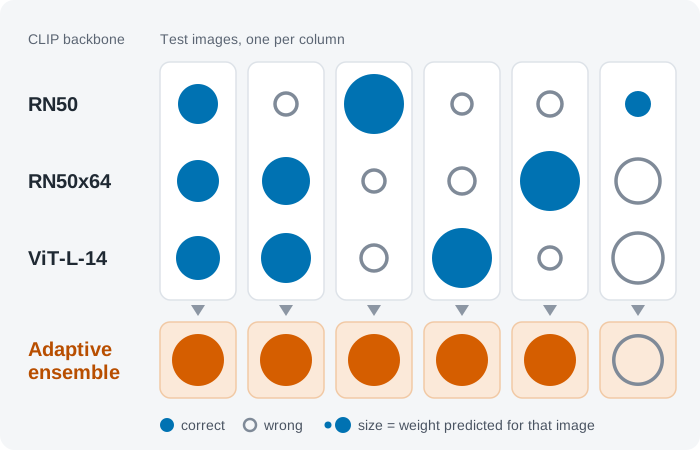
  1. Synergy and Diversity in CLIP: Enhancing Performance Through Adaptive Backbone Ensembling
    C. Rodriguez-Opazo, E. Abbasnejad, D. Teney, Hamed Damirchi, E. Marrese-Taylor, and A. van den Hengel
    In 13th International Conference on Learning Representations (ICLR), 2025
  2. arXiv
    Decomposing Task Vectors for Refined Model Editing
    Hamed Damirchi, E. Abbasnejad, Z. Zhang, and J. Shi
    arXiv preprint arXiv:2512.22511, 2025
  3. arXiv
    The Quest for Winning Tickets in Low-Rank Adapters
    Hamed Damirchi, C. Rodriguez-Opazo, E. Abbasnejad, Z. Zhang, and J. Shi
    arXiv preprint arXiv:2512.22495, 2025

2023

  1. IROS
    Graph-Based Visual-Kinematic Fusion and Monte Carlo Initialization for Fast-Deployable Cable-Driven Robots
    R. Khorrambakht, Hamed Damirchi, M. R. Dindarloo, A. Saki, S. A. Khalilpour, H. D. Taghirad, and S. Weiss
    In IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2023
  2. CVIU
    Action Capsules: Human skeleton action recognition
    A. F. Bavil, Hamed Damirchi, and H. D. Taghirad
    Computer Vision and Image Understanding, 2023
  3. ICRA
    UVO.png
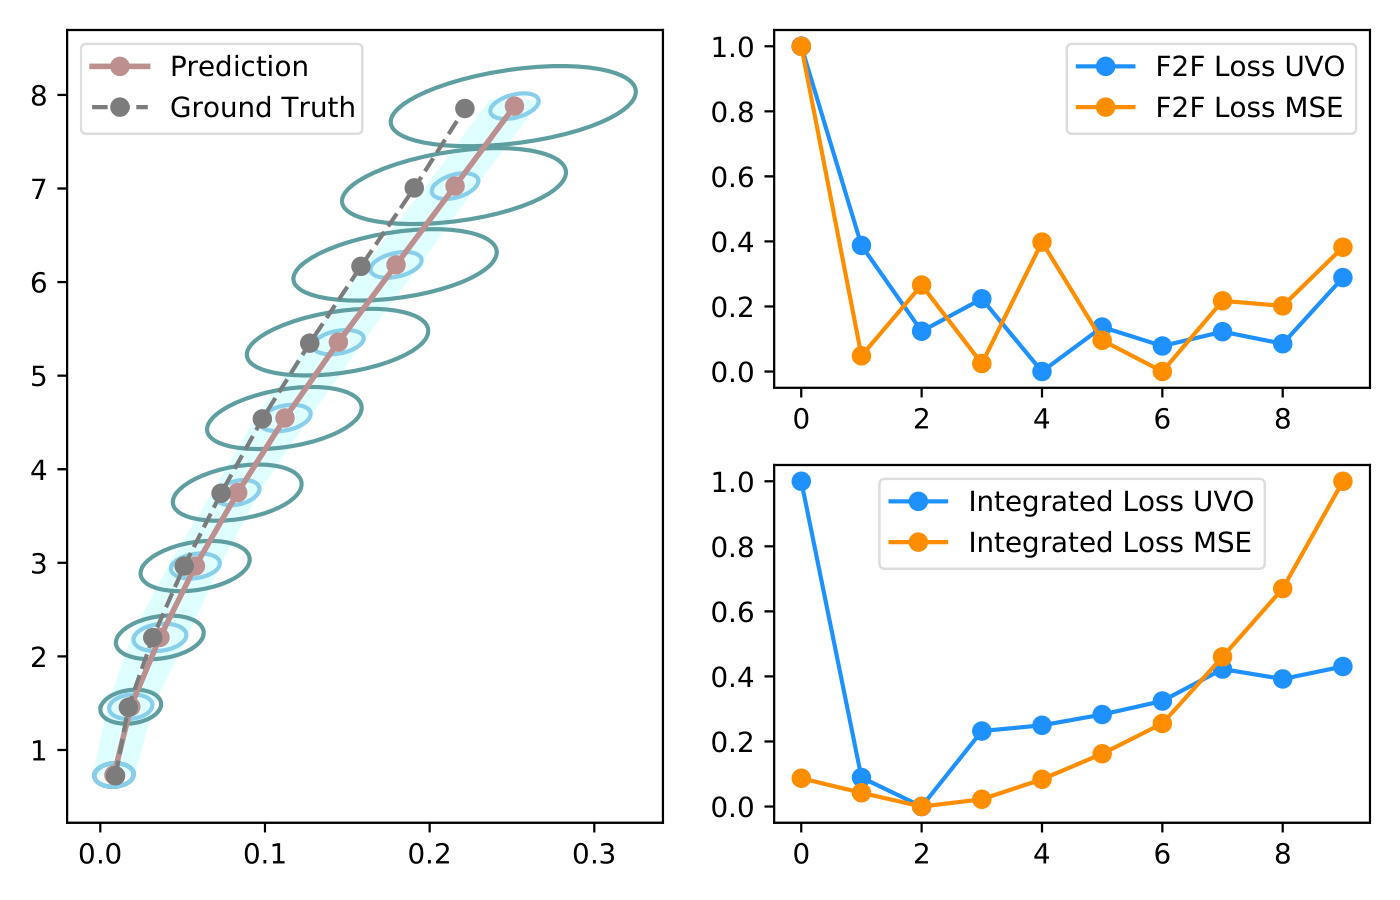
    A Consistency-Based Loss for Deep Odometry Through Uncertainty Propagation
    Hamed Damirchi, R. Khorrambakht, H. D. Taghirad, and B. Moshiri
    In IEEE International Conference on Robotics and Automation (ICRA), 2023
  4. Workshop
    Independent Modular Networks
    Hamed Damirchi, F. Agostinelli, and P. Jamshidi
    In ICRA 2023 Workshop on effective Representations, Abstractions, and Priors for Robot Learning (RAP4Robots), 2023
  5. arXiv
    Unveiling Backbone Effects in CLIP: Exploring Representational Synergies and Variances
    C. Rodriguez-Opazo, E. Marrese-Taylor, E. Abbasnejad, Hamed Damirchi, I. M. Jara, F. Bravo-Marquez, and A. van den Hengel
    arXiv preprint arXiv:2312.14400, 2023
  6. arXiv
    Zero-shot Retrieval: Augmenting Pre-trained Models with Search Engines
    Hamed Damirchi, C. Rodriguez-Opazo, E. Abbasnejad, D. Teney, J. Q. Shi, S. Gould, and A. van den Hengel
    arXiv preprint arXiv:2311.17949, 2023

2022

  1. tinyML
    preintegration.png
    IMU Preintegrated Features for Efficient Deep Inertial Odometry
    R. Khorrambakht, Hamed Damirchi, and H. D. Taghirad
    In tinyML Research Symposium, 2022

2021

  1. MSD
    Tip-trajectory tracking control of a deployable cable-driven robot via output redefinition
    S. A. Khalilpour, R. Khorrambakht, Hamed Damirchi, H. D. Taghirad, and P. Cardou
    Multibody System Dynamics, 2021
  2. arXiv
    Deep Inertial Odometry with Accurate IMU Preintegration
    R. Khorrambakht, C. X. Lu, Hamed Damirchi, Z. Chen, and Z. Li
    arXiv preprint arXiv:2101.07061, 2021

2020

  1. ICMLA
    capsnet.png
    ARC-Net: Activity Recognition Through Capsules
    Hamed Damirchi, R. Khorrambakht, and H. D. Taghirad
    In 19th IEEE International Conference on Machine Learning and Applications (ICMLA), 2020
  2. arXiv
    Exploring Self-Attention for Visual Odometry
    Hamed Damirchi, R. Khorrambakht, and H. D. Taghirad
    arXiv preprint arXiv:2011.08634, 2020

2019

  1. ICRoM
    arasiref.png
    ARAS-IREF: An Open-Source Low-Cost Framework for Pose Estimation
    Hamed Damirchi, R. Khorrambakht, and H. D. Taghirad
    In 7th International Conference on Robotics and Mechatronics (ICRoM), 2019
  2. ICRoM
    calib.png
    A Calibration Framework for Deployable Cable Driven Parallel Robots with Flexible Cables
    R. Khorrambakht, Hamed Damirchi, S. A. Khalilpour, and H. D. Taghirad
    In 7th International Conference on Robotics and Mechatronics (ICRoM), 2019
  3. ICRoM
    Stabilization of Cable Driven Robots Using Interconnection Matrix: Ensuring Positive Tension
    M. R. J. Harandi, S. A. Khalilpour, Hamed Damirchi, and H. D. Taghirad
    In 7th International Conference on Robotics and Mechatronics (ICRoM), 2019
  4. ICEE
    Point-to-Point Motion Control of an Underactuated Planar Cable Driven Robot
    M. R. Jafari Harandi, Hamed Damirchi, S. A. Khalilpour Seyedi, and H. D. Taghirad
    In 27th Iranian Conference on Electrical Engineering (ICEE), 2019